Robot Control
Impedance Control Explained: How Humanoid Robots Learn Safe Contact
Impedance control shapes force and motion so humanoid robots can work safely around people, objects, floors, and unexpected contact.
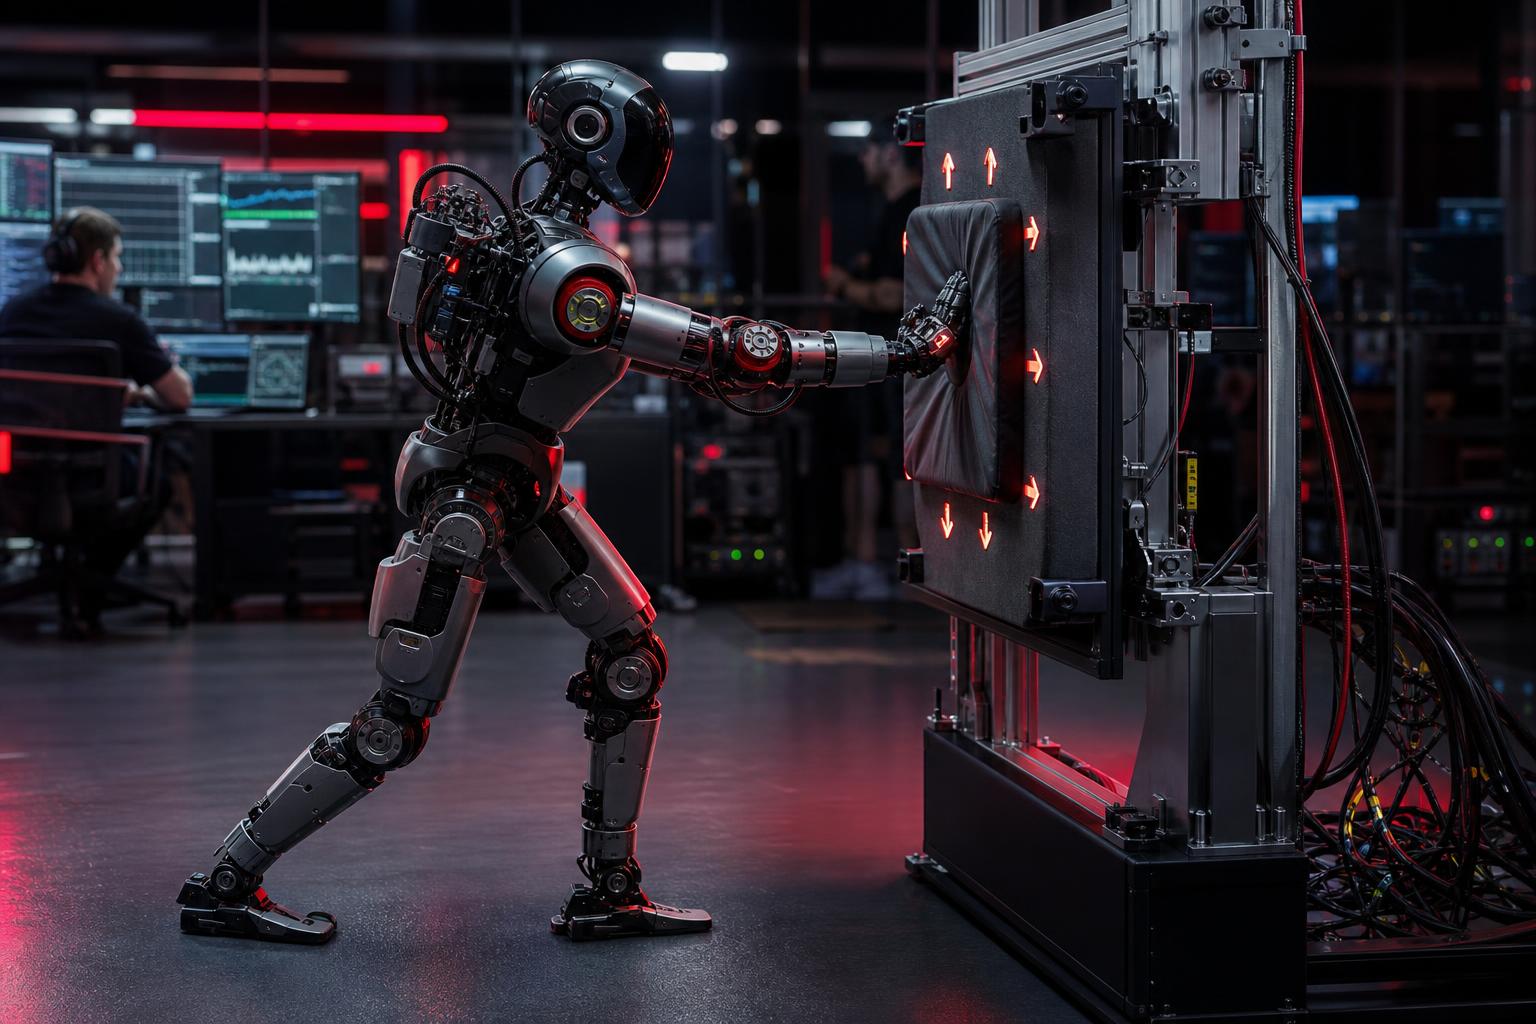
A humanoid robot that cannot manage contact is only a walking demo. Real work means bumping boxes, leaning into doors, carrying loads, bracing on rails, handing objects to people, and recovering when the floor or task pushes back. Impedance control is one of the core ideas that lets a robot choose how stiff, soft, compliant, or resistant its body should feel during those interactions.
The concept sounds abstract, but the field use is concrete. A robot arm placing a part should be stiff along the insertion axis only when alignment is right. A humanoid shoulder near a person should yield before it hurts someone. A leg landing on uncertain ground should absorb energy instead of bouncing. Compliance is not weakness. It is controlled physical behavior.
Key Stats
6 DoF
Typical Force-Torque Sensor
1 kHz
Control Loop Scale
N/m
Stiffness Units
Nm/rad
Joint Stiffness Units
Impedance in Plain English
Mechanical impedance describes how a system responds when force and motion meet. A stiff wall has high impedance. A pillow has low impedance. A spring, damper, and mass all have different relationships between force, displacement, and velocity. A robot with impedance control tries to shape that relationship instead of only commanding a position or a torque.
That matters because pure position control can be dangerous in contact. If a robot insists that its hand must occupy a point already occupied by a table, the controller may drive force upward until something slips, bends, or breaks. Torque control gives more direct force authority, but it still needs a strategy for how the robot should behave when contact changes.
Impedance control provides that strategy. The controller can make an end effector behave as if it has a virtual spring and damper. Push it lightly and it yields. Push it harder and it resists according to the chosen stiffness and damping. Change the task and the virtual properties change.
Humanoids need this because they work through contact at many places at once: feet, hands, forearms, torso, knees, and sometimes the object they carry. Interaction is not an edge case. It is the job.
Impedance Versus Admittance
Impedance and admittance control are often discussed together. In impedance control, the robot generates force behavior from motion error. In admittance control, the robot measures an external force and converts it into a motion command. The distinction matters because hardware changes what is practical.
A lightweight, torque-controlled humanoid joint can often implement impedance-like behavior directly because the actuator can regulate torque and respond quickly. A stiff industrial robot with accurate force-torque sensing may use admittance control, measuring contact force and adjusting position so it behaves compliantly even though the underlying mechanism is stiff.
Neither method is universally better. The choice depends on actuator backdrivability, sensor quality, payload, bandwidth, safety needs, and task. A robot polishing a surface, guiding a human, or inserting a connector may use different control modes across the same limb.
The buyer-facing question is simpler: can the robot control contact forces reliably in the tasks it claims? The answer should be backed by measured force data, not only smooth video.
Control Modes Compared
| Mode | What It Commands | Strength | Risk |
|---|---|---|---|
| Position control | Where the joint or hand should go | Accurate free-space motion | Can push too hard on contact |
| Torque control | How much joint torque to apply | Direct interaction authority | Needs good models and safety limits |
| Impedance control | Virtual stiffness and damping | Natural contact behavior | Tuning can be task-specific |
| Admittance control | Motion response to measured force | Useful for stiff robots with sensors | Sensor delay can destabilize contact |
Why Humanoids Need Variable Compliance
A human changes stiffness constantly. You tense your arm to lift a heavy box, relax when shaking hands, stiffen your ankle on a stable step, and soften your knee when landing. Humanoid robots need a machine version of that behavior. Fixed stiffness is too blunt for human environments.
Variable compliance lets one robot handle different contact goals. In a warehouse, it may keep the torso stiff while carrying a tote, soften the wrist while sliding the tote onto a shelf, and keep the ankles responsive during a turn. In a home, it may use low impedance around people and higher impedance for opening a stuck drawer.
This is where whole-body control connects to impedance. The robot must decide not only how the hand behaves, but how the feet, hips, torso, and free arm support the contact. Pushing with a hand changes ground reaction forces. Carrying a box changes center of mass. Bracing against a wall changes balance.
A compliance policy that ignores the rest of the body can create a new failure. The hand may be gentle while the robot steps poorly. Real humanoid contact control is distributed across the machine.
Hardware: Actuators, Sensors, and Bandwidth
Impedance control depends on hardware. Backdrivable actuators, low reflected inertia, torque sensing, current sensing, series elastic elements, and high-rate controllers all improve the robot ability to behave compliantly. A joint with high friction and slow control cannot convincingly imitate a soft spring.
Force-torque sensors help at wrists, ankles, and contact tools. Joint torque sensors or motor-current estimates can provide broader feedback. Tactile sensors in hands can add local contact information. Cameras and depth sensors identify likely contacts before they happen. The controller then blends planned motion with measured physical response.
Bandwidth matters because contact happens fast. A foot impact, hand bump, or object slip can occur faster than a high-level AI model can reason. Low-level control loops often run at hundreds of hertz to around a kilohertz, while perception and planning run slower. Good robots separate those layers.
The practical test is stability under surprise. If a person nudges the robot, a tote shifts, or a foot lands on a cable, the machine should dissipate energy and recover rather than amplify the error.
Learning Compliance
Classical impedance control uses models and hand-tuned gains. Newer work combines it with learning. Reinforcement learning, imitation learning, human demonstrations, and fleet data can help choose compliance settings for different tasks. The robot may learn when to be stiff, when to yield, and how much force is normal for a given contact.
This does not remove safety engineering. A learned policy still needs limits on force, speed, joint torque, contact duration, and allowed body regions. Compliance that is learned without constraints can be unpredictable. Compliance that is constrained too tightly may be useless. The engineering art is the middle.
Recent research has explored compliance without expensive force sensors by estimating external forces from motor currents, voltages, Jacobians, and actuator models. That is attractive for lower-cost humanoids because full force sensing everywhere is expensive. The risk is estimation error under friction, temperature changes, or unmodeled contact.
The strongest commercial systems will likely mix model-based control, learned policies, hardware sensing, and conservative safety gates. No single method owns the whole stack.
Deployment Tests That Matter
A robot vendor can show compliance with simple demos: a person pushes the arm, the robot gives way. That is useful but insufficient. Deployment-grade contact control needs repeated task evidence. Can the robot insert parts without jamming? Can it place objects without crushing them? Can it recover when a box catches on a shelf? Can it keep balance while a human bumps it?
Tests should report forces and outcomes. Peak force, average force, contact duration, success rate, near falls, emergency stops, and object damage are more meaningful than a polished montage. For humanoids near people, the safety case should include both intended contact and accidental contact.
Different industries care about different thresholds. Automotive factories may tolerate higher forces around guarded equipment. Hospitals, retail, homes, and eldercare require more conservative interaction. A humanoid compliance settings should be tied to the environment and task, not one global demo mode.
Procurement teams should ask vendors to define the safe operating envelope: payload, reach, speed, floor type, people proximity, object fragility, and recovery behavior. If those limits are vague, the robot is not ready for unsupervised contact-rich work.
Failure Modes
Compliance can fail in several ways. Too stiff, and the robot damages objects or people. Too soft, and it cannot complete the task or hold balance. Too much delay, and the controller oscillates. Poor damping, and contact becomes bouncy. Bad sensing, and the robot reacts to noise or misses a real force.
Humanoids add coupled failures. A compliant wrist can save an object but shift load to the shoulder. A soft knee can absorb impact but destabilize the torso. A yielding torso can protect a person but move the center of mass outside the support polygon. The controller must understand the whole body, not only the contact point.
Thermal limits also matter. Holding compliant force can heat motors, especially in quasi-static tasks such as carrying, bracing, or pushing. A robot may perform a task once and fail after an hour because the joints get hot. Compliance testing should include duration, not only a single event.
The final failure mode is overtrust. A robot that feels gentle in one demo may still be unsafe in another configuration. Contact safety is contextual, measured, and bounded.
What Customers Should Watch in 2026
The first signal is published force data. Humanoid companies increasingly talk about physical AI, whole-body control, and safe interaction. The useful disclosures will include measured contact forces, task success rates, recovery data, and the limits under which tests were run.
The second signal is hardware transparency. Vendors should explain actuator type, torque sensing, wrist or ankle force sensing, tactile sensing, and control rates at a level customers can understand. They do not need to reveal every line of code, but they should not hide the physical basis for safe contact.
The third signal is standards alignment. Humanoid safety standards are still catching up, but ISO 10218, ISO 25785-1, ANSI work, OSHA expectations, and industrial robot safety practice all influence deployment. Compliance control should fit into the safety case instead of being marketed as a replacement for it.
The fourth signal is serviceability. Compliant behavior depends on calibrated joints, sensors, and mechanical condition. A robot with worn gears, drifting torque sensors, or damaged foot pads may not behave like the tested unit. Maintenance records and diagnostics are part of the control system.
Bottom Line
Impedance control is one of the quiet foundations of useful humanoids. It is how robots move from avoiding contact to managing contact. A machine that can tune stiffness and damping across its body can work more safely around people, objects, and uncertain environments.
The market should treat compliance claims as measurable engineering, not personality. Ask for forces, rates, limits, failure cases, and maintenance assumptions. A humanoid that knows when to be strong and when to yield is much closer to real work than one that only walks well in empty space.
FAQ
What is impedance control in robotics?
It is a control method that shapes the relationship between force and motion, often by making the robot behave like a virtual spring and damper during contact.
Is impedance control the same as force control?
It is related but not identical. Impedance control regulates compliant behavior, while direct force control tries to command or regulate a specific force.
Why does it matter for humanoids?
Humanoids must balance, manipulate, brace, and interact with people and objects, so they need controlled compliance across the whole body.
How Compliance Becomes a Product Feature
For a customer, impedance control is not a math term. It is the difference between a robot that can work beside people and a robot that needs a wide empty lane. A warehouse robot that yields when a tote catches on shelving can keep working. A robot that drives through the snag may damage the shelf, drop inventory, or lose balance. The control choice becomes a business outcome.
The same idea applies to handoffs. When a humanoid gives a tool to a person, both sides are moving and both sides have uncertainty. The robot needs enough stiffness to hold the tool steady, enough compliance to tolerate a human grasping it off-center, and enough sensing to release at the right moment. Too much stiffness feels unsafe. Too little stiffness feels useless. The correct behavior changes with object weight, grip, reach, and the person posture.
Compliance is also a maintenance feature. A robot that absorbs small impacts may protect reducers, bearings, wrists, fingertips, and foot pads. A robot that fights every unexpected contact may transfer shock into expensive joints. Over thousands of hours, that difference becomes uptime, part replacement, and service cost. The best humanoid vendors will connect contact control to total cost of ownership, not only safety demos.
There is a software-product angle too. Customers should expect task-specific contact profiles. A palletizing task, hospital delivery task, retail shelf task, and factory inspection task should not share identical stiffness and force thresholds. Mature systems will let operators choose certified modes, log deviations, and lock settings behind safety approvals. That makes compliance auditable instead of improvised.
Fleet learning can improve those modes if it is handled carefully. A robot that records contact forces and outcomes can show engineers where policies are too stiff or too soft. Repeated failures around the same shelf height, tote edge, or floor transition can become training data. The risk is that automatic updates change behavior without adequate validation. Physical AI needs release discipline because software changes can create physical hazards.
The practical benchmark is repeatability. A humanoid should show the same safe contact behavior on Monday morning, Friday night, after a battery swap, after a joint module replacement, and after a software update. Impedance control is useful only if the robot remains calibrated, monitored, and bounded. That is the line between a lab trick and a deployable contact skill.
The Investor Read
For investors, impedance control is a signal about whether a humanoid company understands deployment reality. Walking, waving, and object pickup are table stakes. Contact-rich work is where labor value appears. A company that can show controlled force, safe recovery, and repeatable compliance has a better claim on warehouses, factories, hospitals, and homes than a company showing choreography.
The evidence should be specific. Look for task denominators, not only clips. How many insertions succeeded? What was the peak contact force? How often did the robot enter protective stop? What floor types, payloads, lighting conditions, and operator distances were tested? Did the same policy run on multiple units, or only one tuned prototype? Those answers reveal whether compliance is a product layer or a lab setting.
This also affects margins. Robots that tolerate contact without breaking can work longer, need fewer service calls, and expand into less structured sites. Robots that need perfect conditions remain expensive demonstrations. Contact control is not the whole company, but it is one of the clearest ways to separate useful physical AI from polished motion.
Reader Checklist
The practical takeaway is to ask for measured evidence before accepting a broad claim. Look for test conditions, operating limits, failure cases, maintenance requirements, and a clear explanation of what has already worked outside a controlled demonstration. A strong technical story survives those questions. A weak one turns vague when the numbers are requested.
That checklist is useful because emerging infrastructure markets are full of impressive language. Hardware becomes real when it can be inspected, repeated, serviced, and compared. The best teams publish enough detail for customers, regulators, and partners to understand the tradeoffs before the system is placed in the field.