Actuators
Series Elastic Actuators Explained: How Robots Learn Force
A humanoid robot does not need only strong joints. It needs joints that know how hard they are pushing. Series elastic actuators solve that problem by placing a compliant element, usually a spring or flexure, between the motor gearbox and the output.
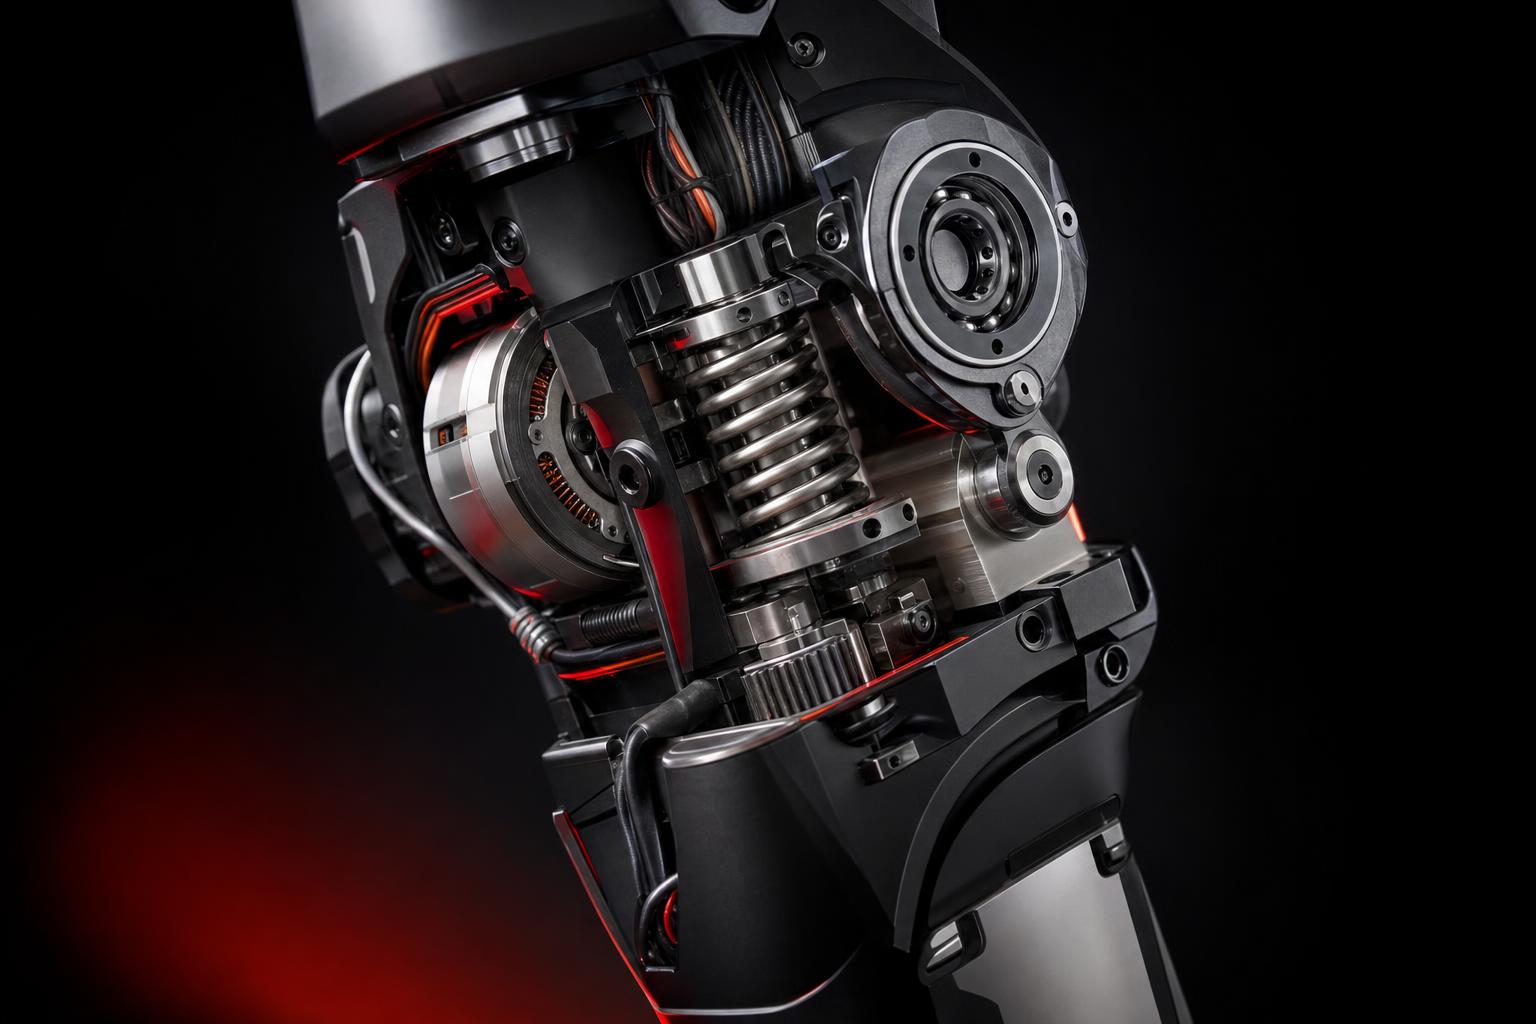
A humanoid robot does not need only strong joints. It needs joints that know how hard they are pushing. Series elastic actuators solve that problem by placing a compliant element, usually a spring or flexure, between the motor gearbox and the output link. The robot measures deflection across that element and turns motion into force information.
The idea dates to the 1995 work of Gill Pratt and Matthew Williamson at MIT, and it still shapes legged robots, exoskeletons, prosthetics, collaborative arms, and humanoid research platforms. The reason is simple: when a robot touches the world, stiffness becomes both a performance tool and a liability.
Key Stats
1995
MIT SEA Paper
F=Kx
Force Estimate
ms
Impact Time Scale
3
Core Tradeoffs
The Basic Architecture
A rigid actuator tries to connect motor torque to joint output as directly as possible. A series elastic actuator inserts compliance in series with the load. The motor turns through a gearbox, the gearbox pushes on a spring element, and the spring pushes the joint. A position sensor measures how much the spring deflects. If the spring constant is known, output force or torque can be estimated from Hooke's law: force equals stiffness times displacement.
That sounds like adding softness to a machine that wants precision. In practice, the softness makes certain kinds of precision easier. Gearboxes create friction, backlash, reflected inertia, and torque ripple. A compliant element can isolate some of those effects from the output. The controller can regulate spring deflection, which is a position problem, instead of trying to infer force through a stiff drivetrain.
The architecture is not one design. Some SEAs use linear springs, torsion springs, flexures, elastomers, load-cell-like structures, or compound mechanisms. Some are rotary, some linear, some hydraulic, some electric. The common idea is measurable compliance between actuation and output.
Why Force Control Matters
Humanoids live in contact. Walking is contact. Picking up a tote is contact. Leaning on a table is contact. Opening a door, bracing during a slip, and handing an object to a human all require force management. A robot that only commands position can look accurate in free space and become dangerous or useless when the environment pushes back.
Force control lets the robot decide not only where a limb should go but how hard it should interact. A foot should accept load without bouncing. A hand should close around an object without crushing it. An arm should push a cart with enough force to move it while complying with unexpected resistance. A torso should absorb impact when balance recovery fails. These are not edge cases. They are the work.
Series elasticity helps because it creates a built-in force sensor and a mechanical buffer. When the robot hits the ground, the spring deflects before the shock reaches the motor and gearbox. When the robot needs to regulate contact, the controller can use deflection as a torque signal. That combination is why SEAs became common in legged robotics research and exoskeleton work.
The Tradeoff: Bandwidth Versus Safety
Compliance is not free. A softer spring improves shock tolerance and force resolution, but it can reduce control bandwidth. The joint cannot change output force faster than the motor, spring, sensor, and controller allow. A stiffer spring improves bandwidth and position behavior, but it reduces the protective and sensing benefits that made the SEA attractive.
Humanoid designers choose spring stiffness around the task. A walking robot needs enough bandwidth to respond to ground contact and balance disturbances. An assistive exoskeleton needs low impedance and user safety. A warehouse humanoid may need high payload capability and repeatability. A research platform may accept lower efficiency for better observability. There is no universal SEA stiffness.
The tradeoff is one reason quasi-direct-drive actuators became popular. A low-ratio, high-torque motor can be backdrivable and torque controllable without a large compliant element. Many modern legged robots use that approach. But series elasticity still matters when impact tolerance, force fidelity, or human interaction is central. The design question is not whether compliance is good. It is where to put it and how much to use.
Comparison Table
| Architecture | Strength | Weakness | Common Use |
|---|---|---|---|
| Rigid geared actuator | High position stiffness | Poor impact tolerance and difficult torque sensing | Industrial arms, precise fixtures |
| Series elastic actuator | Force fidelity and shock tolerance | Bandwidth and packaging tradeoffs | Legged robots, exoskeletons, force-controlled arms |
| Quasi-direct drive | Backdrivability and dynamic torque response | Large motors, thermal limits, lower gear advantage | Quadrupeds, humanoid legs, agile platforms |
| Variable stiffness actuator | Adjustable compliance | Mechanical complexity and cost | Research, prosthetics, human interaction |
What the Controller Sees
A series elastic joint turns torque estimation into a sensor problem. The controller reads motor position, output position, and spring deflection. If the spring model is linear, torque is proportional to deflection. If the spring model is nonlinear, the controller needs calibration or a learned model. Several research groups have shown that learning the elasticity of an SEA can improve torque accuracy compared with a simple linear spring assumption.
The measurement chain has to be good. Encoder resolution, sensor noise, mechanical hysteresis, temperature drift, and spring aging all affect torque estimates. A beautiful SEA on paper can perform poorly if the deflection sensor is noisy or the spring model changes under load. That is why commercial actuator modules spend so much effort on calibration, thermal behavior, and integrated electronics.
Control loops can be layered. A low-level loop regulates motor current and spring deflection. A middle loop controls joint torque or impedance. A whole-body controller decides how forces should be distributed across feet, hands, and contacts. The actuator is only one layer, but its behavior limits everything above it.
Why Humanoids Do Not All Use the Same Answer
Humanoid companies make different actuator choices because their robots have different jobs. A lab humanoid optimized for dynamic walking may favor torque bandwidth. A home-assistance robot may favor safety and quiet compliance. A factory robot may favor durability, payload, and serviceability. A low-cost educational platform may favor simpler geared joints and software limits.
Series elasticity also competes with external force sensors, joint torque sensors, motor current estimation, tactile skin, foot force plates, and software observers. A designer can place sensing at the actuator, the joint, the foot, the hand, or the whole robot model. Each location sees different information. SEA deflection is direct and useful, but it is not the only source of force knowledge.
The best designs treat compliance as a system property. Some compliance is mechanical. Some is software impedance control. Some is in rubber feet, belts, link flex, grippers, or contact surfaces. A humanoid that looks rigid may still have controlled compliance. A humanoid with springs may still behave dangerously if the control stack is poor.
Where Series Elasticity Still Wins
SEAs remain strong in applications where physical interaction is constant and unpredictable. Exoskeletons need to apply assistive torque without fighting the user. Prosthetics need comfort, impact absorption, and controlled push-off. Legged robots need to handle ground contact uncertainty. Collaborative arms need to limit forces and detect contact. In all of these cases, compliance is not a concession. It is part of the interface.
The architecture also helps during failures. A rigid drivetrain can transmit impact straight into gears, bearings, and structure. A compliant element can absorb energy and give software a measurable warning. That does not make a robot safe by itself, but it gives the safety system more time and better signals.
For humanoids moving into real workplaces, this matters because demos are forgiving and operations are not. Floors are uneven, boxes shift, tools jam, humans bump into machines, and balance recovery fails. The actuator that survives the mistake may be more valuable than the actuator that performs best in a clean lab clip.
What Buyers Should Ask
A robot buyer does not need to know every spring constant, but actuator architecture should still be part of technical diligence. The useful questions are practical. How is joint torque measured? What happens during an unexpected impact? Can the joint be backdriven by a human? How much reflected inertia reaches the contact point? What torque bandwidth is available at the output, not only at the motor?
Serviceability matters too. Elastic elements can fatigue. Sensors can drift. Gearboxes wear. Calibration can change after a hard collision. A humanoid sold for warehouse work needs a maintenance story for joints that experience thousands of contacts per day. If torque sensing depends on a carefully calibrated compliant element, the vendor should explain how that calibration is checked in the field.
The deeper point is that actuator claims must be tied to tasks. A joint that is excellent for walking may be poor for precision assembly. A joint that is safe around people may struggle with heavy impacts. A joint that delivers high peak torque may overheat in continuous work. Series elasticity is one tool in that design space, not a universal badge of sophistication.
How Series Elasticity Shows Up in Behavior
A good series elastic actuator is felt more than seen. The robot plants a foot and accepts load without a sharp bounce. It nudges an object and adjusts force instead of pushing through. It catches an unexpected contact with less gear shock. In a teleoperated system, the operator may feel smoother interaction because the low-level controller is regulating force instead of only position.
For walking, the benefit appears during impact and stance. A foot strike is not a clean mathematical event. The surface may be angled, soft, slippery, or cluttered. Compliance gives the controller a short mechanical buffer while sensors estimate what happened. That buffer can reduce peak loads and improve the quality of ground reaction force control. The robot still needs good planning and balance, but the actuator makes the contact less brittle.
For manipulation, the story is different. A hand or arm with force-sensitive joints can press, insert, scrape, and hold with better control. The actuator does not replace tactile sensing at the fingers, but it helps the arm understand contact forces upstream. When a robot opens a heavy door, slides a bin, or leans into a fixture, joint-level force control can keep the motion stable even when the environment resists.
There are failure modes. A compliant joint can oscillate if the controller is poorly tuned. A spring can saturate under high load. A soft actuator can feel sluggish in precise positioning. A torque estimate can drift if the spring model changes. These are engineering problems, not reasons to dismiss the architecture. They explain why actuator design, controls, calibration, and task definition have to be developed together.
The next generation of humanoids will likely hide much of this complexity inside sealed modules. Buyers may see a joint rating, a payload rating, and a safety claim, not the internal compliance design. That makes independent testing more important. Drop tests, impact tests, backdrivability measurements, continuous torque tests, and force-control benchmarks will reveal more than marketing language.
The Supply Chain Angle
Series elastic designs also affect sourcing. A robot company needs springs or flexures with tight tolerances, encoders with enough resolution to measure small deflections, compact packaging, reliable mechanical stops, and control electronics that can close loops quickly. Those parts must survive vibration, thermal cycling, dust, impacts, and service handling. The actuator is a product inside the product.
For startups, the choice is build or buy. Building a custom SEA can create better performance for a specific robot, but it consumes engineering time and manufacturing effort. Buying an integrated actuator module can speed development, but it may lock the robot into another company's torque limits, communication protocol, thermal design, and maintenance model. The more humanoid companies move toward production, the more this tradeoff matters.
The winners in the joint supply chain will likely sell more than motors. They will sell validated torque behavior, calibration tools, failure data, replacement procedures, and software interfaces. In humanoid robotics, the actuator vendor that can prove contact performance may become as important as the company selling the AI stack.
How to Benchmark Force-Controlled Joints
Benchmarking a force-controlled joint requires more than measuring peak torque. Useful tests include torque tracking under changing loads, impact recovery, backdrive force, thermal behavior during repeated contact, sensor drift after shock, and low-speed smoothness. A joint that looks strong on a dynamometer may still perform poorly when a humanoid has to place a foot quietly or hold a fragile object.
Bandwidth should be measured at the output. Motor current response is not enough because gears, belts, springs, and software filters all sit between the motor and the world. Engineers care about how quickly commanded torque becomes contact force, how much overshoot appears, and how the system behaves near saturation. Those numbers determine whether whole-body control can trust the actuator during balance recovery.
Repeatability is just as important. A humanoid fleet cannot rely on hand-tuned joints that behave differently from robot to robot. If elastic elements vary, if calibration drifts, or if assembly tolerances change torque estimates, the control software has to absorb that variation. Production robotics rewards boring consistency. Series elasticity is useful only when it can be manufactured, calibrated, and serviced repeatedly.
The Practical Takeaway
The actuator debate is really a contact debate. Humanoids that work in homes, warehouses, labs, and factories will spend their useful lives touching things that move, bend, slip, or surprise them. Series elasticity remains important because it gives the machine a measurable layer between command and contact. That layer can be the difference between a robot that only poses and a robot that can work.
The 12-Month Outlook
Expect more hybrid answers. Humanoid developers will keep using compact high-torque motors, harmonic or cycloidal reducers, torque sensors, elastic elements, and software impedance in different combinations. The winning module may not be a textbook SEA. It may be a quasi-direct-drive joint with calibrated flexure sensing, a stiff actuator plus high-quality torque sensor, or a variable compliance mechanism in only the most contact-rich joints.
The supply chain is moving toward integrated joint modules because robot companies do not want to design every motor, reducer, brake, encoder, driver, thermal path, and cable harness from scratch. If those modules include reliable torque sensing and controlled compliance, they will shape humanoid design as much as AI models do. Physical AI still needs physical joints.
The durable lesson from series elastic actuators is that force is not an afterthought. Robots that work around people and unstructured objects must feel what they are doing. Whether the sensing comes from a spring, a strain gauge, motor current, tactile skin, or a learned observer, useful humanoids need contact intelligence at the hardware level.
FAQ
What is a series elastic actuator? It is an actuator that places a compliant element between the motor drivetrain and the output load, then measures deflection to estimate force or torque.
Why do robots use SEAs? They improve force control, reduce reflected drivetrain effects, provide shock tolerance, and help robots interact safely with uncertain environments.
Do all humanoid robots need SEAs? No. Some use quasi-direct-drive joints, torque sensors, or software impedance control instead. The right answer depends on payload, bandwidth, safety, cost, and task requirements.